




Detachable modular design
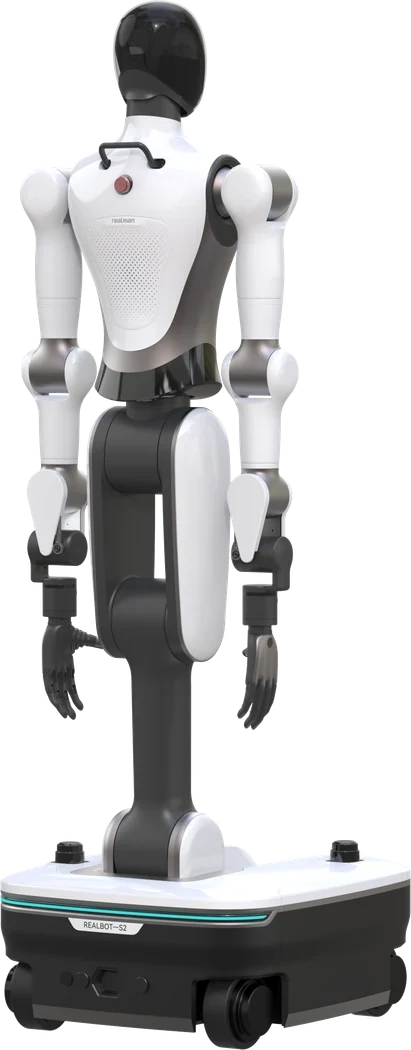
The upper body (head, arms, and torso) can be detached from the wheeled base and mounted on different chassis or dual-arm platforms, allowing the same manipulator to be used for different tasks.
INDUSTRIAL & LOGISTICS ROBOTS · REALMAN
Humanoid manipulation robot with a detachable wheeled base and 21 degrees of freedom.
RealMan RealBot-01 is a wheeled humanoid robot with 21 degrees of freedom, consisting of a detachable wheeled base and a humanoid upper body. It is designed for data collection, training, and production applications, with multiple depth cameras, LiDAR, and a perception-manipulation package comprising two arms.
SELECT BY TASK
RealMan RealBot-01 is a humanoid robot that combines a wheeled mobile base with a detachable upper body comprising the head, arms, and torso in a single system. Since the upper body is designed to attach to different chassis, the same manipulator hardware can be used on both stationary and mobile platforms. For effective perception, it includes multiple depth cameras, fisheye cameras, single-line LiDAR, an IMU, and a head-mounted microphone array; tactile sensors are optional. Two 7-axis RX75 arms, together with the shoulder, waist, and head axes, provide a total of 21 active degrees of freedom; its mobility capabilities and compact chassis dimensions make it suitable for working in confined spaces.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
The upper body (head, arms, and torso) can be detached from the wheeled base and mounted on different chassis or dual-arm platforms, allowing the same manipulator to be used for different tasks.
A total of 21 active degrees of freedom; the high number of axes in both arms, along with the waist, leg, and neck axes, provides manipulation flexibility.
Both arms use 7-axis RX75 arms; various grippers and dexterous hands can be fitted along with end effectors to suit task requirements.
Five depth cameras, three fisheye cameras, single-line LiDAR, two IMUs, and a head-mounted microphone array provide 3D reconstruction, object and gesture recognition, and autonomous navigation.
Camera options are available for the data collection and standard versions; different depth cameras can be selected to suit task-focused use.
Designed for narrow corridors with a compact chassis and shoulder width; the ability to turn in place makes maneuvering in tight spaces easier.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | 1680 mm tall; 570 mm length × 465 mm width (chassis and shoulder width under 465 mm) |
| Weight | Approximately 125 kg |
| Arm reach | Horizontal reach 1818 mm (excluding end effector) |
| Arm payload | 5 kg (single arm) |
| Maximum speed | 0,1-1,5 m/s |
| Turning radius | 690 mm (turning in place) |
| Battery | 40 Ah (BMS-supported); charging time approximately 2 hours |
| Charging time | Approximately 2 hours |
| Modes of movement | Wheeled base; turns in place, turning radius 690 mm; chassis and shoulder width under 465 mm for narrow corridor passage |
| Degrees of freedom | 21 active DoF: arms 14, waist 3, legs 2, neck 2 |
| Arm degrees of freedom | 7 (RX75) |
| End effector | A multi-axis dexterous hand or gripper can be added according to task requirements; compatible with OYMotion, BrainCo and Zhixing grippers and hands |
| Material | Modular architecture: detachable wheeled base and humanoid upper body comprising the head, arms and torso; the upper body can be mounted on other chassis models or RealMan dual-arm platforms |
| Arms | Two RX75 arms: 7 axes per arm, 5 kg payload, built-in six-axis force-torque sensor (200 N / 7 N·m, %0,5 FS) |
| Reach | Vertical reach 2100 mm; horizontal reach 1818 mm (excluding end element) |
| Torso | Waist 3 axes, legs 2 axes, neck 2 axes; upper body can be detached from the base |
| Chassis | Wheeled base; 690 mm turning radius in place; 0,1-1,5 m/s |
| Sensors | 5 depth cameras, 3 fisheye cameras (130° field of view; chest, back and base), 1 single-line LiDAR (range over 40 m at %90 reflectivity), 2 IMUs, head-mounted microphone array, optional tactile sensors |
| Interfaces | Orbbec 335LG in the data collection version, Intel RealSense D405 camera in the standard version; RealSense D435 optional; compatible with RX75, RM75 and RM65 arms; JSON and Modbus protocols, C, C++, C#, Python SDK, ROS and ROS 2 packages |
| Interaction | Circular smart speaker with 6 microphones (optional audio module) |
| Software features | 3D reconstruction, obstacle detection, object and gesture recognition, autonomous navigation, sound source localization, contact detection |
SEE THE PRODUCT IN ACTION
The introduction video linked from the source product page opens when you press the play button.
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
A wheeled humanoid robot combining a detachable wheeled base and humanoid upper body, with 21 active degrees of freedom; equipped with multiple depth cameras, LiDAR and two RX75 arms, it is intended for data collection, training, retail and manufacturing applications.
Yes. The upper body, comprising the head, arms and torso, can be removed from the wheeled base and mounted on different chassis or other RealMan platforms.
The only difference is the camera hardware; the data collection version comes with a different depth camera, while the other chassis and sensor hardware remain the same.
Multi-axis dexterous hands or grippers can be installed depending on the task; the system is designed to be compatible with grippers and dexterous hands from different manufacturers.
Yes. Its compact chassis and shoulder width make it suitable for operating between narrow shelves and in corridors.
IN THE SAME CATEGORY
 Industrial & logistics robots
AgiBot
Wheeled, dual-arm industrial interactive operations robot.
 Industrial & logistics robots
RealMan
Full-size wheeled dual-arm humanoid robot with a lift column.
 Industrial & logistics robots
RealMan
Full-size wheeled humanoid robot with folding legs; provides 0–2,1 m of vertical reach
NEXT STEP
Start by defining your work area, task, and integration requirements.