




Folding legs and wheeled mobility
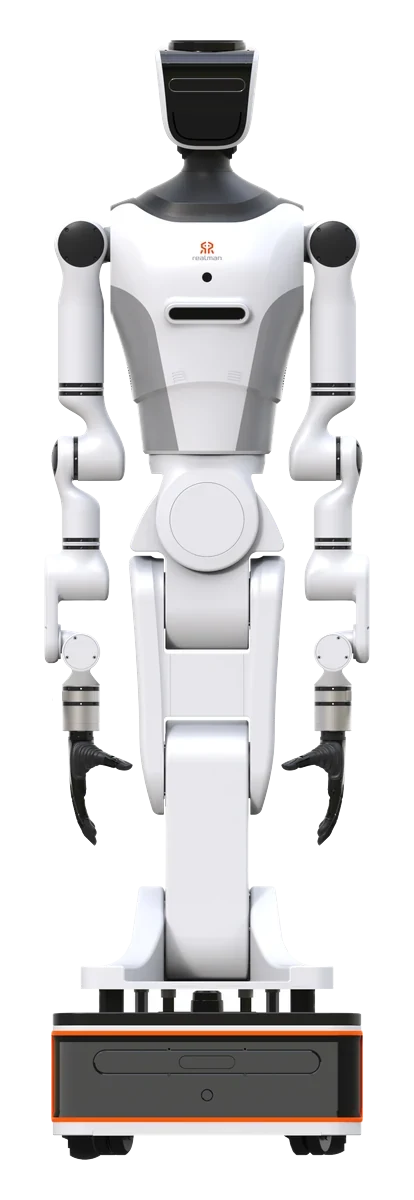
Folding legs with ankle and knee axes and a four-steering, four-drive chassis; the legs fold and extend to enable operation at different heights, from the floor to upper shelves.
INDUSTRIAL & LOGISTICS ROBOTS · REALMAN
Full-size wheeled humanoid robot with folding legs; provides 0–2,1 m of vertical reach
RealBot-S2 is a full-size wheeled humanoid robot with folding legs. With 20 active axes, two 7-axis arms, and integrated vision/navigation systems, it is designed for data collection, service, and manufacturing applications.
SELECT BY TASK
RealBot-S2 is a full-size wheeled humanoid platform with folding legs in the RealMan Robotics family. The lower body features folding legs with ankle and knee axes and a four-steering, four-drive chassis; the legs fold to let the arms work closer to the ground and extend to reach a height of 2,1 m. The computing unit and perception sensors enable advanced visual processing; multiple charging options and the mobile platform design support a variety of task scenarios.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
Folding legs with ankle and knee axes and a four-steering, four-drive chassis; the legs fold and extend to enable operation at different heights, from the floor to upper shelves.
Hardware modules can be quickly removed; on-site part replacement speeds up maintenance, while OTA software updates support remote operation and maintenance processes.
The platform supports batteries that can be charged manually, through battery replacement, or at an automatic station, providing flexibility for different operational needs.
The combination of a six-axis force-torque sensor on each arm and a quickly interchangeable parallel gripper at the end effector, with dexterous hands, enables precise grasping and manipulation.
The onboard high-performance computing unit and sensor suite are designed to support visual processing and local navigation decisions.
With a vertical working range of 0–2,1 m and an approximately 0,69 m reach, it can perform both low- and high-level tasks on a single platform.
The combination of a wheeled chassis and folding legs enables movement and interaction with the environment across different ground conditions, expanding the range of tasks.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | 1700 mm tall; 614 × 552 mm footprint |
| Weight | Approximately 125 kg |
| Arm reach | 0,69 m (excluding end effector) |
| Arm payload | 5 kg (single arm) |
| Maximum speed | 0,1-1,5 m/s |
| Climbing angle | 8°; obstacle crossing up to 20 mm |
| Obstacle and step | Obstacle crossing up to 20 mm (four-steering, four-wheel-drive chassis) |
| Navigation | Dual LiDAR navigation |
| Battery | 48 V 20 Ah; manual charging, battery replacement, and automatic charging station |
| Operating time | Approximately 6 hours of typical operation |
| Modes of movement | Four-steering, four-wheel-drive chassis; SLAM navigation and localization, dynamic obstacle avoidance; multi-level operation with folding legs and a 0,3 m lift stroke |
| Degrees of freedom | 20 active DoF (excluding base and end effector): 7 per arm, 2 in the head (pitch, yaw), 2 in the waist (pitch, yaw), 2 in the legs (ankle, knee) |
| Arm degrees of freedom | 7 DoF |
| End effector | Quick change between a two-finger parallel gripper and a five-finger dexterous hand |
| Material | Quick-release modules: rapid maintenance and upgrades, OTA remote operation and maintenance; reach 0,69 m (excluding end effector); six-axis force-torque sensor 200 N / 7 N·m, %0,5 FS; no display, optional tablet |
| Torso | Folding legs (ankle, knee); head and waist with pitch and yaw axes; 0,3 m lift stroke; vertical working range 0-2,1 m |
| Arms | Two 7-axis arms in a humanoid configuration; 5 kg per arm; reach 0,69 m; force-torque sensor 200 N / 7 N·m |
| Chassis | Four-steering, four-wheel-drive; 0,1-1,5 m/s; 8° slope; 20 mm obstacle |
| Maintenance | Quick-release modules; OTA remote operation and maintenance; manual charging, battery replacement, and automatic charging station |
| Sensors | Head: 1 stereo RGB camera + 2 fisheye cameras (360-degree field of view); hands: RGB-D camera (standard), monocular RGB (optional); dual LiDAR navigation; six-axis force-torque sensor |
| Interfaces | JSON and Modbus protocols; C, C++, C#, Python SDK; ROS and ROS 2 packages |
| Connectivity | Wired, Wi-Fi, and optional 5G |
| Wireless | Wired, Wi-Fi, 5G (optional) |
| Interaction | Voice interaction: onboard microphone array and speaker |
| Processor | NVIDIA Jetson AGX Orin 64 GB |
| Software features | Multi-level operation with a folding wheeled platform; SLAM navigation and localization, dynamic obstacle avoidance; quick-release modules and OTA remote operation and maintenance |
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
RealBot-S2 is a full-size wheeled humanoid robot with folding legs. Its lower body consists of folding legs and a four-steering, four-wheel-drive chassis; it includes two 7-axis arms, stereo and fisheye cameras in the head, RGB-D cameras in the hands, dual LiDAR, and high-performance computing.
Folding legs with ankle and knee axes allow the arms to reach the ground or the platform to move into a higher-reach position, making it possible to perform both low- and high-level tasks with the same platform.
Hardware modules are designed for quick removal; OTA (remote) software update and diagnostic features also support operation and maintenance without a site visit.
The platform is suitable for data collection and model training, domestic services, retail tasks, and industrial production and assembly support applications.
Environmental perception is provided primarily by stereo RGB and fisheye cameras, RGB-D cameras in the hands, and dual LiDAR; the end effector supports quick changes between a two-finger parallel gripper and a five-finger dexterous hand.
IN THE SAME CATEGORY
 Industrial & logistics robots
AgiBot
Wheeled, dual-arm industrial interactive operations robot.
 Industrial & logistics robots
RealMan
Humanoid manipulation robot with a detachable wheeled base and 21 degrees of freedom.
 Industrial & logistics robots
RealMan
Full-size wheeled dual-arm humanoid robot with a lift column.
NEXT STEP
Start by defining your work area, task, and integration requirements.