




Four high-frequency scenarios
The manufacturer defines four main use cases for Cruzr Y1 that are frequently repeated in factories; each focuses on tasks that regularly arise in production.
INDUSTRIAL & LOGISTICS ROBOTS · UBTECH
Industrial autonomous decision-making humanoid robot with Co-Agent capabilities
UBTECH Cruzr Y1 is a humanoid robot based on industrial embodied intelligence. It is designed to operate in variable manufacturing scenarios, transitioning from commanded operation to autonomy and featuring the Co-Agent capability highlighted by the manufacturer.
SELECT BY TASK
UBTECH Cruzr Y1 is an industrial-grade humanoid robot developed for tasks in manufacturing and logistics that are repeated but involve variable inputs. The manufacturer positions the robot as an agent (Co-Agent) capable of making autonomous decisions in situations that challenge conventionally programmed arms. Cruzr Y1 highlights capabilities such as recovering from irregularities in scenarios including palletizing, sorting, and machine-tool tending; self-correction after slipping or tipping; and synchronization with the production cycle. Delivery, configuration, and commissioning conditions for enterprise projects are assessed on a project-by-project basis.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
The manufacturer defines four main use cases for Cruzr Y1 that are frequently repeated in factories; each focuses on tasks that regularly arise in production.
With its ability to handle unsorted, mixed, or irregular materials, the robot takes on tasks in situations that challenge conventional fixed-program automation.
According to the manufacturer's description, Cruzr Y1 exhibits behaviors intended to minimize downtime by independently recovering from events such as slipping or tipping.
The robot is configured with an embodied intelligence layer that enables the transition from command-based operation to autonomous decision-making, and the manufacturer-defined Co-Agent architecture.
Cruzr Y1 can be synchronized with the loading/unloading cycles of CNC or molding machines for continuous machine-tending tasks.
With the ability to recover disordered stacks during palletizing, the robot supports applications beyond conventional palletizing automation.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Modes of movement | Dual-arm humanoid body on a wheeled base; operates around production lines and machines |
| End effector | One end effector per arm (2 total); RGBD cameras on the wrists |
| Structure and materials | Dual-arm body on a wheeled base. |
| Joint module | Joint module. |
| Sensors | RGBD camera on the head; RGBD cameras on the wrists x2; LiDAR, array TOF x2, and binocular cameras x2 on the wheeled base |
| Interaction | Operation screen, status indicator lights x4, manual push handle |
| Processor | The manufacturer describes Co-Agent as an embodied intelligence brain and the first industrial agent for humanoid robots. |
| Software features | It is reported to be able to recognize and sort unordered, mixed, and irregular materials, and to self-correct slips and topples. |
SEE THE PRODUCT IN ACTION
The introduction video linked from the source product page opens when you press the play button.
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
Tasks suited to the four high-frequency scenarios defined by the manufacturer—repetitive tasks with variable inputs, such as palletizing, sorting, and machine tending—are suitable for Cruzr Y1.
It is said to be designed to detect irregularities such as slipping or toppling and correct them autonomously, enabling it to collect and process unordered and mixed items.
The manufacturer positions the robot with an embodied intelligence layer and the Co-Agent architecture; this configuration aims to enable a transition from command-based operation to autonomous behaviors.
IN THE SAME CATEGORY
 Industrial & logistics robots
AgiBot
Wheeled, dual-arm industrial interactive operations robot.
 Industrial & logistics robots
RealMan
Humanoid manipulation robot with a detachable wheeled base and 21 degrees of freedom.
 Industrial & logistics robots
RealMan
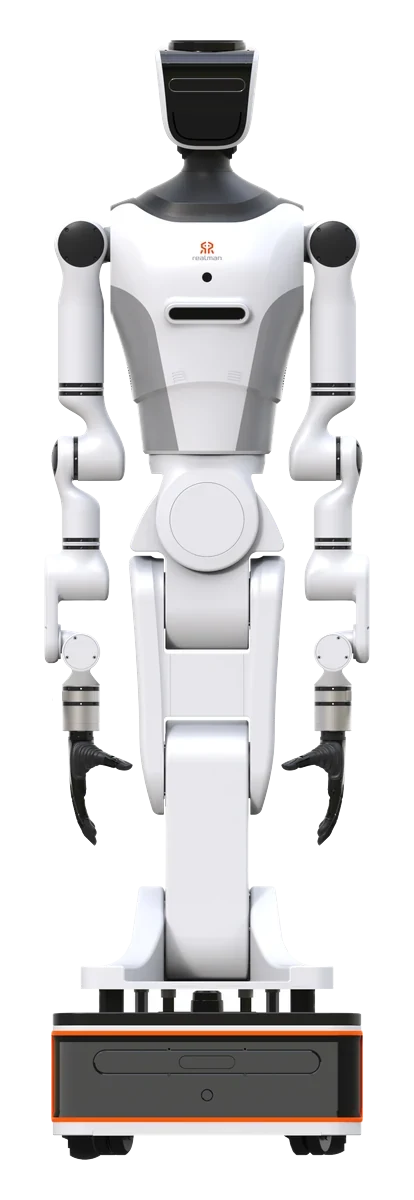
Full-size wheeled dual-arm humanoid robot with a lift column.
NEXT STEP
Start by defining your work area, task, and integration requirements.