




Compact yet powerful design
Its compact standing dimensions and lightweight design provide maneuverability in tight spaces and portability; the structure is designed to meet industrial requirements.
QUADRUPED ROBOTS · AGIBOT
Compact, industrial-grade quadruped exploration and inspection robot.
AgiBot D1 Ultra offers an industrial-grade quadruped platform with a compact body, high-torque joints, and modular connections. Supporting autonomous navigation and various sensors, it is suitable for use in rescue, security, and research.
SELECT BY TASK
AgiBot D1 Ultra, as an industrial-grade member of the D1 series, provides a compact yet durable quadruped platform. Built with aluminum alloy shafts and protected components, the platform accepts hardware such as modular I/O, LiDAR, depth cameras, RTK, and cellular modems. Its 12 degrees of freedom and high-torque joints enable movements such as walking over challenging terrain, climbing stairs, and vertical jumping. IP54 protection, an operating temperature range, and support for open SDK/URDF/Isaac Sim make it suitable for secondary development, sensor integration, and task-oriented applications. Detailed user manuals and technical documents are published in the AgiBot documentation center.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
Its compact standing dimensions and lightweight design provide maneuverability in tight spaces and portability; the structure is designed to meet industrial requirements.
IP54-rated protection provides resistance to water splashes, dust, and muddy environments, supporting field operations.
High-torque joints and reinforcement-learning-based gait control provide adaptability to different terrain types and anti-tipping behavior.
Standard interfaces such as Ethernet, USB, SBUS, and UART allow the integration of LiDAR, depth cameras, RTK, and cellular modems.
Support for open SDK, URDF, and Isaac Sim enables platform integration for software development, simulation, and custom tasks.
High peak torque at every joint and an impact-resistant motor design are intended to provide reliable torque for loaded operation and challenging terrain.
The packing list is intended for field use and includes the robot body, battery, charging unit, remote control with display, and transport equipment.
Designed to accommodate the sensors and software components required for autonomous navigation, mapping, and data collection tasks.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | 630 × 360 × 420 mm (Length × Width × Height) |
| Dimensions (folded) | 670 × 435 × 145 mm (folded) |
| Weight | 16 kg |
| Load capacity | 5 kg (payload) |
| Maximum speed | 3,7 m/s |
| Climbing angle | 30° standard, up to 40° |
| Obstacle and step | 16 cm (continuous stair climbing) |
| Jumping | Vertical jump 35 cm |
| Joint torque — source field | 48 Nm |
| Battery capacity | Approximately 199 Wh (4,6 Ah × 43,2 V) |
| Battery | Removable battery: rated 5 Ah, nominal 4,6 Ah, 43,2 V; charging dock and adapter included as standard |
| Operating time | 1-2 hours |
| Range | 6 ± 1 km range; charging approximately 1 hour (from 10% to 90%) |
| Charging time | Approximately 1 hour (%10-90 charge) |
| Charger | Adapter standard, charging station standard |
| Modes of movement | Quadruped; 12 degrees of freedom (3 per leg), RL-based gait control |
| Degrees of freedom | 12 (3 per leg) |
| Joint motor | Dual-encoder joint control; no zero-position calibration required, ready to use at startup |
| Torque density | Peak joint torque 48 Nm; actuator specific power 2 kW/kg |
| Material | Aluminum alloy and high-strength engineering plastic; vacuum-pressed aluminum shafts, sealed and corrosion-resistant core components; IP54; 16 kg |
| Manufacturer's note | The manufacturer states a stable operating time of 200 hours in harsh environments; values are based on laboratory testing. The target-tracking function requires further development by the user. |
| Joint configuration | 12 degrees of freedom, 3 per leg; 12 aluminum-alloy precision joint motors |
| Joint torque — source field (2) | Peak joint torque 48 Nm; drive system specific power 2 kW/kg |
| Joint range of motion | Range of motion: body -28° / +28°, thigh -170° / -66°, calf +35° / +156° |
| Joint control | Dual-encoder control; no zero calibration required, ready at startup; impact-resistant, long module life |
| Protection | IP54; vacuum-pressed aluminum alloy shafts, sealed protection and anti-corrosion treatment for core components; 200 hours of stable operation in extreme environments |
| Packaging | Carrying case 80 × 45 × 25 cm; included in the case: robot, battery, charging dock, adapter and 5 adapter cables, screen-equipped remote control, manual, carrying bag, 4 non-slip feet, tool set |
| Sensors | IMU (standard); 1920 × 1080 camera, DFOV 122°, HFOV 111°, VFOV 70°; real-time video transmission |
| Interfaces | Ethernet ×1 (RJ45, 1000 Mbps), USB ×2, power output ×2, SBUS ×1, UART ×1; compatible with 3D LiDAR, depth camera, RTK, 4G, video transmission, and tracking modules |
| Connectivity | Wi-Fi 5.0 2,4 GHz, Bluetooth 5.0; 4G/5G and video transmission modules can be installed |
| Wireless | Wi-Fi 5.0 (2,4 GHz, 21 dBm) and Bluetooth 5.0; screen-equipped remote control |
| Joint encoder | Dual encoder; no zero-position calibration required |
| Software features | Reinforcement learning (RL)-based gait control: self-balancing, fall prevention, disturbance resistance; target tracking; standard movements (standing, lying down, damping mode, pitch and height adjustment, turning in place) and special movements (forward and upward jumps, standing on two legs, backflip, waving); SDK, URDF model, and Isaac Sim and MuJoCo simulation |
| Expansion module | Ethernet ×1, USB ×2, power port ×2, SBUS ×1, UART ×1 |
| Protection rating | IP54 |
| Operating temperature | 0-40 °C |
SEE THE PRODUCT IN ACTION
The introduction video linked from the source product page opens when you press the play button.
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
Its standing dimensions are 630 × 360 × 420 mm, and its mass including the battery is specified as 16 kg. Dimensions in the lying position are provided in the source document.
The platform is designed to perform maneuvers such as walking, climbing stairs, and vertical jumping, with 12 degrees of freedom; maximum speed and jump values are listed in the source.
The device has an IP54 protection rating and is specified for an operating range of 0–40 °C; components are treated against corrosion.
Integration of LiDAR, depth cameras, RTK, and 4G/5G modems is supported through ports such as Ethernet, USB, SBUS, and UART; Wi-Fi and Bluetooth connections are also available.
With support for the open SDK, URDF, and Isaac Sim, users can create secondary developments, simulations, and custom task software; detailed user manuals and technical documents are available in the document center.
IN THE SAME CATEGORY
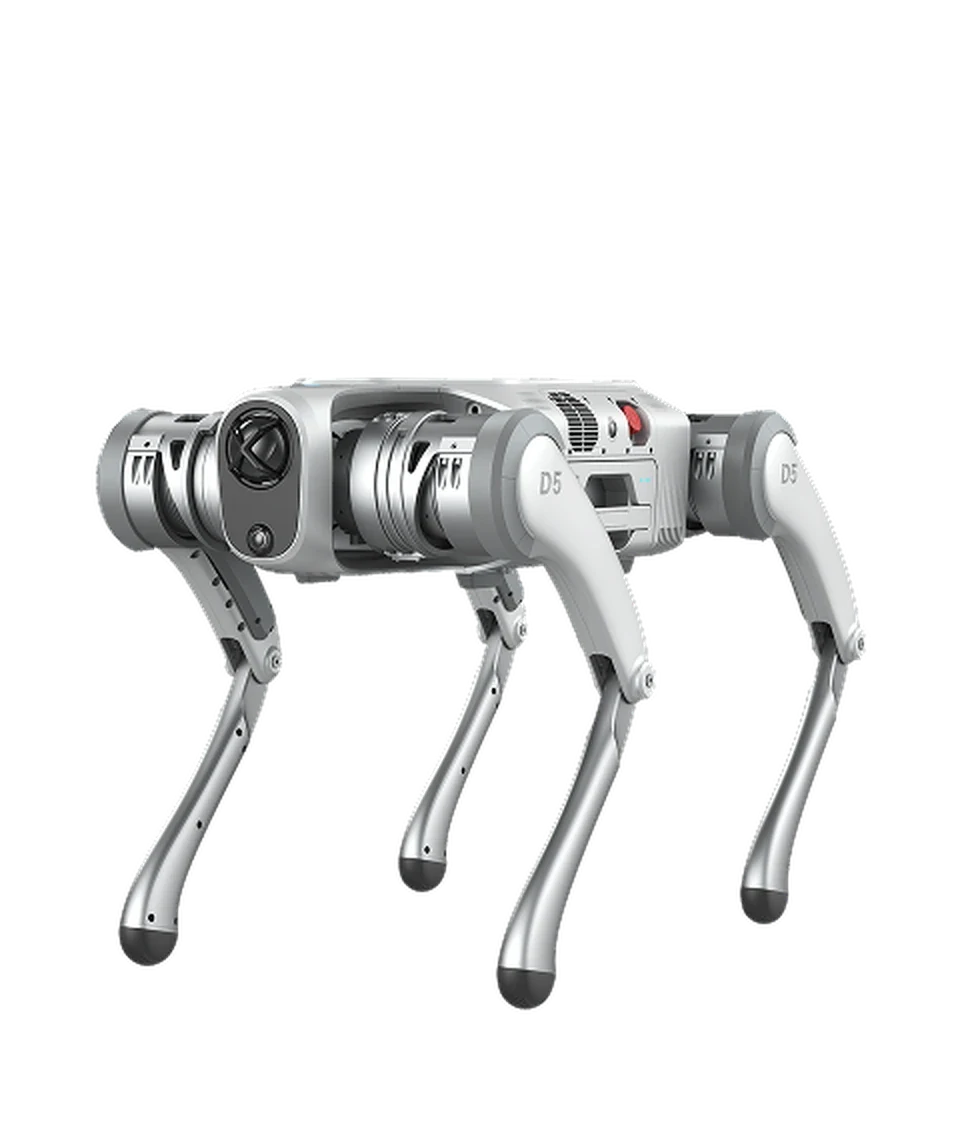 Quadruped robots
PUDU
Industrial autonomous quadruped robot for challenging environments
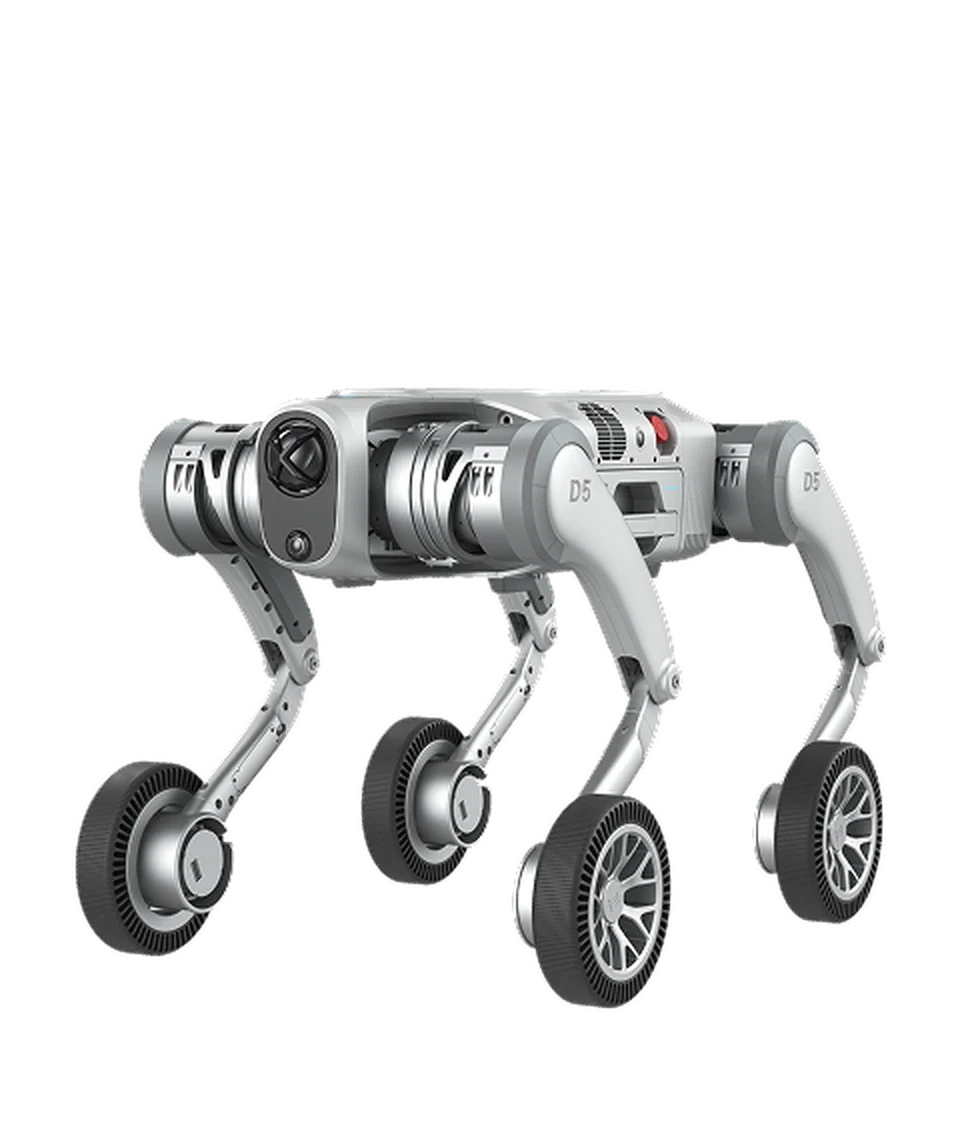 Quadruped robots
PUDU
Industrial-grade autonomous quadruped robot
 Quadruped robots
Unitree
Compact size, industrial capability
NEXT STEP
Start by defining your work area, task, and integration requirements.