




Dual-arm manipulation
The two arms enable simultaneous picking from shelves and carrying; the maximum total payload capacity with both arms is specified as 50 kg.
INDUSTRIAL & LOGISTICS ROBOTS · GALBOT
Dual-arm autonomous warehouse and logistics robot for carrying heavy loads.
Galbot S1 is a dual-arm heavy-payload robot designed for warehouse and logistics applications. Its two arms provide a total payload capacity of 50 kg and a wide working area for shelf access.
SELECT BY TASK
Galbot S1 is a platform developed for dual-arm manipulation and material handling tasks in industrial, warehouse, and logistics environments. Its mechanical design and sensor configuration focus on operations requiring shelf access, flexible handling, and autonomous navigation. Its dual-arm structure provides a total payload capacity of 50 kg; with a horizontal reach of 0–2400 mm and a vertical reach of 2390 mm measured from the wrist center, it can reach upper shelf levels. Its base is mounted on omnidirectional wheels, and its comprehensive perception package (3D LiDAR at the head and base, depth cameras, force sensors) provides dedicated perception for both navigation and work within shelves. The computing unit is a high-performance AGX Orin configuration; its power system is designed for long-duration operation using replaceable batteries.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
The two arms enable simultaneous picking from shelves and carrying; the maximum total payload capacity with both arms is specified as 50 kg.
With a horizontal working range of 0–2400 mm and a vertical range of 2390 mm, measured from the wrist center, it can reach the upper shelf levels.
LiDAR and depth cameras located in the head, chest, and base handle shelf-height detection and ground navigation with separate sensors, allowing manipulation and movement tasks to support one another.
The four-wheel, rotary omnidirectional base provides maneuverability and stable transport in warehouse aisles.
The onboard high-performance computing unit is designed to perform autonomous decision-making and perception tasks.
The dual-battery system and hot-swappable batteries make it possible to replace a battery without shutting down the robot, providing operational flexibility for continuous-operation scenarios.
Supports basic user interaction through a 7-inch touchscreen and speakers; network connections are provided via Wi‑Fi and Bluetooth.
Items such as a wireless remote control, wired charger, and wireless emergency stop are included as standard equipment.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | Maximum height 1793 mm; arm length 920 mm (shoulder to wrist); lift stroke 750 mm; working range from wrist center: horizontal 0-2400 mm, vertical 2390 mm |
| Weight | 320 kg |
| Arm reach | Arm length (shoulder to wrist) 920 mm; working range (wrist center): horizontal 0-2400 mm, vertical 2390 mm |
| Lifting height | 750 mm (lift stroke) |
| Arm payload | Maximum 50 kg with both arms |
| Maximum speed | 1,5 m/s |
| Navigation | GalbotSDK navigation capabilities: mapping, localization, dynamic obstacle avoidance, and point-to-point autonomous navigation |
| Battery | 48 V 30 Ah × 2; charging time 2 hours; hot swapping supported |
| Battery voltage | 48 V |
| Operating time | 8 hours; 24/7 operation with hot-swappable dual batteries |
| Charging time | 2,0 hours (single battery, adapter) |
| Charger | Wired charger: standard equipment |
| Modes of movement | Four-wheel rotary omnidirectional base; maximum speed 1,5 m/s |
| Degrees of freedom | Neck 2, 7 per arm, lift 1 |
| Arm degrees of freedom | 7 DoF |
| Neck degrees of freedom | 2 DoF |
| Torque density | Maximum payload of 50 kg with both arms; chest-mounted six-axis force sensor ×2 |
| Material | Four-wheel rotary omnidirectional base; base dimensions 730 × 730 mm |
| Manufacturer's note | Charging time with a single-battery adapter is 2,0 hours; hot battery swapping supported. Wireless remote control, wired charger, and wireless emergency stop are standard equipment; the body has a power button and an emergency stop switch. |
| Joint configuration | Degrees of freedom: neck 2, 7 per arm, and lift 1 |
| Load capacity | Maximum 50 kg with both arms; working range from wrist center: horizontal 0-2400 mm, vertical 2390 mm |
| Battery system | Two 48 V 30 Ah batteries; 8 hours of operation, 2 hours to charge, uninterrupted operation with hot swapping |
| Structure and materials | Maximum height 1793 mm, weight 320 kg; base 730 × 730 mm |
| Safety | Wireless emergency stop is standard; power and emergency stop buttons on the body; two 3D LiDAR units on the base |
| Sensors | Head: binocular camera ×1, 3D LiDAR ×1. Chest: depth camera ×2, six-axis force sensor ×2. Base: 3D LiDAR ×2 |
| Connectivity | WiFi 2,4 and 5 GHz; Bluetooth 5.2; USB 3.0 ×2 and Ethernet |
| Interaction | 7-inch touchscreen; 5 W speaker ×2 |
| Display | 7-inch touchscreen |
| Processor | NVIDIA AGX Orin 64 GB, 275 TOPS |
| Software features | Runs on the AstraBrain embodied intelligence foundation model; wireless remote control, wired charger, and wireless emergency stop are standard equipment |
| Operating temperature | 0-40 °C; 0-90% relative humidity, non-condensing |
SEE THE PRODUCT IN ACTION
The introduction video linked from the source product page opens when you press the play button.
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
Technical information provided for Galbot S1: maximum height 1793 mm, weight 320 kg, arm length from shoulder to wrist 920 mm, lifting stroke 750 mm. Degrees of freedom: 2 for the neck, 7 per arm, and 1 for the lift. Computing is specified as NVIDIA AGX Orin 64 GB; operation for 8 hours with two 48 V 30 Ah batteries and a charging time of approximately 2 hours are documented. The base measures 730 × 730 mm and is a four-wheel omnidirectional type; the source includes maximum speed information.
Battery architecture enables uninterrupted operation: the two-battery, hot-swappable design allows batteries to be changed without shutting down the robot. To maintain continuity, the number of spare batteries and charging infrastructure should be planned as part of the project; these factors determine operating time in practice.
Perception is provided from three locations: a stereo camera and 3D LiDAR in the head, two depth cameras and two six-axis force sensors in the chest, and two 3D LiDARs in the base. The base LiDARs are used for floor-level perception and navigation, while the head LiDAR is used for shelf height and arm operations.
The document specifies an operating range of 0–40 °C and relative humidity of 0–90% (non-condensing); these ranges cover typical environmental conditions for warehouses and indoor facilities.
IN THE SAME CATEGORY
 Industrial & logistics robots
AgiBot
Wheeled, dual-arm industrial interactive operations robot.
 Industrial & logistics robots
RealMan
Humanoid manipulation robot with a detachable wheeled base and 21 degrees of freedom.
 Industrial & logistics robots
RealMan
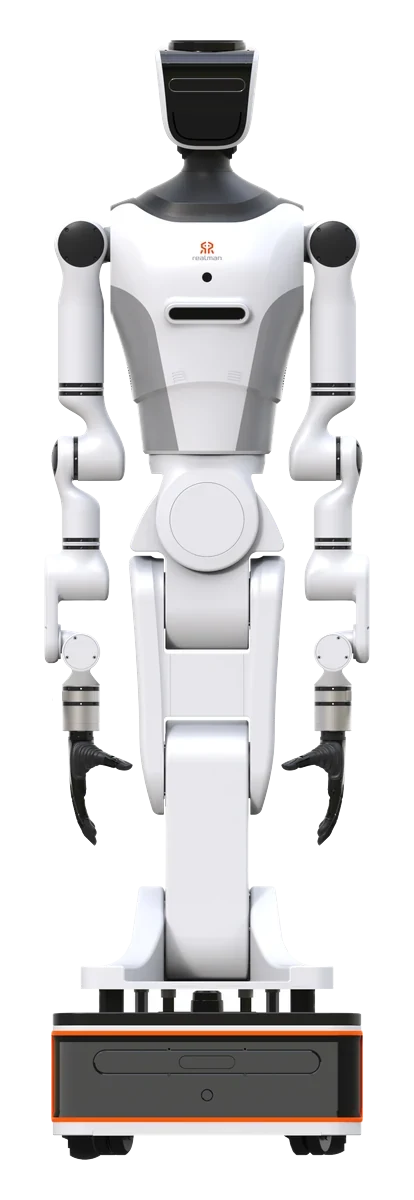
Full-size wheeled dual-arm humanoid robot with a lift column.
NEXT STEP
Start by defining your work area, task, and integration requirements.