




RM65-B-V arm
The 6-axis RM65-B-V arm provides precise single-arm manipulation, offers a suitable solution for light-payload applications, and is compatible with the RM65 series platform.
INDUSTRIAL & LOGISTICS ROBOTS · REALMAN
Single-arm mobile manipulator with vertical lifting and a 6-axis RM65 arm.
RealMan Single-Arm Lift is a single-arm mobile manipulator with a 900 mm lift column and a 6-axis RM65-B-V arm mounted on an autonomous circular base. Designed to operate in narrow corridors with a compact body, it coordinates all components in a single task plan.
SELECT BY TASK
Single-Arm Lift is a single-arm mobile manipulator with vertical lift developed by RealMan Robotics. It combines a 505 mm-diameter autonomous base, a lift column with a 900 mm effective stroke, and a 6-axis RM65-B-V arm on a single platform. The system manages base navigation, lifting motion, and arm control in a single task plan; the repeatability of the RM65 arm series and the vertical reach of the lift column enable flexible task configurations in manufacturing, logistics, and service environments. The device is suitable for autonomous operations, with maneuvering in narrow aisles between shelves, SLAM-based positioning, and LiDAR-assisted obstacle avoidance. JSON/Modbus protocols, C/C++/C#/Python SDKs, and ROS and ROS 2 packages are supported for development and integration.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
The 6-axis RM65-B-V arm provides precise single-arm manipulation, offers a suitable solution for light-payload applications, and is compatible with the RM65 series platform.
The lift column provides an effective stroke of approximately 900 mm, enabling flexibility for multi-level operations; it offers vertical reach for tasks both above shelves and at floor level.
The 505 mm-diameter base and small turning radius allow it to change direction in narrow corridors and turn on the spot; its compact form factor offers an advantage in mobile applications.
It offers autonomous navigation with SLAM-based route planning and LiDAR-assisted obstacle detection; it provides body-level integration for positioning accuracy and safe movement.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | 1605 mm tall; 505 mm-diameter circular base |
| Weight | Approximately 100 kg |
| Lifting height | Approximately 900 mm lift stroke |
| Arm payload | 5 kg (RM65-B-V arm) |
| Maximum speed | 1 m/s |
| Turning radius | 252,5 mm |
| Positioning accuracy | <±5 cm |
| Navigation | Autonomous SLAM |
| Battery | Charging supply: 100-240 V AC 50 Hz; operating voltage: 24 V DC |
| Operating time | 3 hours |
| Charger | 100-240 V AC 50 Hz charging supply |
| Operating voltage | 24 V DC system supply |
| Modes of movement | 505 mm-diameter omnidirectional circular base; 252,5 mm turning radius on the spot; autonomous SLAM navigation, positioning accuracy under ±5 cm |
| Degrees of freedom | 6 DoF arm + 1 lift axis |
| Arm degrees of freedom | 6 DoF |
| Material | Lift stroke no less than 900 mm; RM65 series 6-axis humanoid-configuration arm (610 mm working radius, 7,2 kg, ±0,05 mm repeatability) |
| Arm | RM65-B-V: 6 axes, 5 kg payload, humanoid configuration; RM65 series 610 mm working radius, 7,2 kg, ±0,05 mm repeatability |
| Lifting | Effective lift stroke no less than 900 mm; height adjustment for multi-level operations |
| Base | 505 mm-diameter circular base; 252,5 mm turn-in-place radius; 1 m/s; positioning accuracy under ±5 cm |
| Power | 100-240 V AC 50 Hz charging; 24 V DC operating voltage; 3 hours of operation |
| Sensors | Autonomous SLAM navigation (manufacturer does not publish sensor inventory) |
| Interfaces | JSON and Modbus protocols; C, C++, C#, Python SDK; ROS and ROS 2 packages; 24 V DC system voltage |
| Connectivity | Autonomous SLAM navigation; positioning accuracy under ±5 cm |
| Software features | Whole-body control: base, lift column, and arm coordinated in a single task plan; autonomous route planning; precise single-arm manipulation |
| Operating temperature | 5-40 °C |
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
A single-arm mobile manipulator with vertical lift, designed for compact autonomous tasks. It features a 505 mm-diameter autonomous base, a 900 mm lift column, and a 6-axis RM65-B-V arm.
The lift column provides approximately 900 mm of effective travel; access to different shelf and surface levels is determined through planning in combination with the RM65 arm’s working radius.
Yes. The compact circular base is designed to change direction and turn in place in narrow aisles, using LiDAR-assisted obstacle avoidance while moving.
The system provides several hours of runtime and can be charged using a 100–240 V AC supply; its 24 V DC operating voltage powers operation.
JSON and Modbus protocols, C/C++/C#/Python SDKs, and ROS and ROS 2 packages are supported for development and integration.
IN THE SAME CATEGORY
 Industrial & logistics robots
AgiBot
Wheeled, dual-arm industrial interactive operations robot.
 Industrial & logistics robots
RealMan
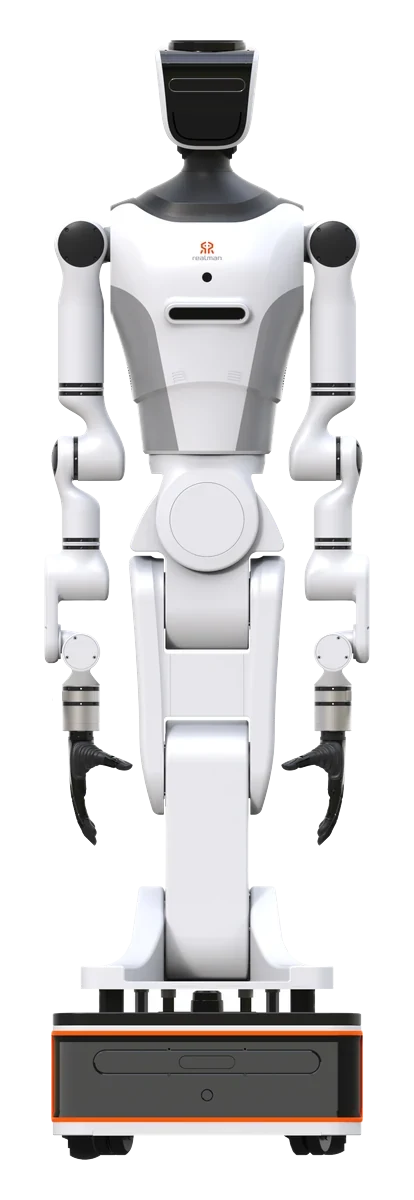
Humanoid manipulation robot with a detachable wheeled base and 21 degrees of freedom.
 Industrial & logistics robots
RealMan
Full-size wheeled dual-arm humanoid robot with a lift column.
NEXT STEP
Start by defining your work area, task, and integration requirements.