




Reinforcement learning-based locomotion
Gait control offers self-adaptation, making it easier to move while maintaining balance across different surfaces and situations.
QUADRUPED ROBOTS · AGIBOT
A quadruped robot platform featuring reinforcement learning-based locomotion and expansion support.
AgiBot D1 is a 15,5 kg quadruped robot platform available in Pro and Edu versions. It provides balance, agility, and expansion/integration options through reinforcement learning-based control.
SELECT BY TASK
AgiBot D1 is offered in two versions (Pro and Edu) as a quadruped robot dog platform. Its hardware includes an aluminum alloy body and 12 joint motors, designed to enable movement over challenging terrain with high torque and fast operation. Thanks to reinforcement learning-based locomotion control, the robot can adapt to environmental conditions and maintain its balance; fall protection and the ability to start operating immediately with zero calibration are also notable features. The D1 Edu version allows broad interface access and sensor integration for development, while the D1 Pro is geared toward use with a controller and app. The battery, with standard charging and a replaceable design, provides runtime suitable for field tasks; performance figures given under laboratory test conditions may vary in field use.
PRODUCT-SPECIFIC
Features compiled from source product information; evaluate according to the model and configuration.
Gait control offers self-adaptation, making it easier to move while maintaining balance across different surfaces and situations.
Local balance and safety mechanisms protect against tipping and sudden falls, improving mission continuity.
Dual-encoder motors are designed to operate as soon as they are powered on, eliminating the need for lengthy calibration procedures at the start of field operations.
D1 Edu supports the integration of various LiDAR, depth camera, RTK, and mobile communications modules through interfaces such as Ethernet, USB, power, SBUS, and UART.
With a URDF model and compatible simulation environments, software development and algorithm testing can be carried out in simulation before using real hardware.
The robot's standard movements include standing, lying down, damping, and turning horizontally; special movements include demonstration moves such as jumping, standing on two legs, and somersaulting.
The body, designed with an aluminum alloy and engineering plastics, provides mechanical durability and ease of transport in field conditions.
SOURCED PRODUCT DATA
Values are taken from the source product page. Confirm the package, software, and accessory contents against the manufacturer's current documentation before ordering.
| Feature | Value |
|---|---|
| Dimensions (standing) | Approx. 635 × 360 × 420 mm (L × W × H) |
| Dimensions (crouched) | Approx. 675 × 435 × 145 mm (lying down) |
| Weight | 15,5 kg (including battery) |
| Load capacity | 5 kg payload |
| Maximum speed | 3,5 m/s |
| Climbing angle | 40° |
| Obstacle and step | 16 cm (continuous stair climbing) |
| Jumping | 35 cm jump height (from the ground) |
| Joint torque — source field | 48 Nm (peak joint torque) |
| Joint motion range — source field | Body -28°~28°, thigh -170°~66°, lower leg 35°~156° |
| Battery capacity | 4600 mAh |
| Battery | Nominal 4,6 Ah, 43,2 V; charging takes approximately 1 hour (%10'dan %90'a); quick-swappable battery, charging base standard |
| Battery voltage | 43,2 V |
| Operating time | 1-2 hours |
| Range | 6 km ± 1 km |
| Charging time | Approximately 1 hour (%10-90 charge) |
| Charger | Adapter standard, charging station standard |
| Operating power | 3500 W maximum power output |
| Modes of movement | Quadruped; reinforcement learning-based gait control, self-balancing, fall and interference protection |
| Degrees of freedom | 12 (3 per leg) |
| Torque density | Peak joint torque 48 Nm; 3500 W maximum power output, 15,5 kg body |
| Material | Aluminum alloy body and high-strength engineering plastic; 12 aluminum alloy precision joint motors; 15,5 kg |
| Manufacturer's note | Adapter and charging dock are standard; the controller is joystick-type. Charging time was measured at an ambient temperature of 25 degrees, and range was measured at a speed of 1 m/s with no load. The maximum climbing incline is listed as 40 degrees in the product page table, while the official store (store.agibot.com) lists 30 degrees for D1 Pro and D1 Edu. |
| Actuator | High-power-density motion unit; 12 aluminum alloy precision joint motors |
| Joint torque — source field (2) | 48 Nm peak torque; millions of impact-cycle tests; zero calibration with dual-encoder control |
| Joint motion range — source field (2) | Body from -28° to 28°, thigh from -170° to 66°, lower leg from 35° to 156° |
| Body material | Aluminum alloy and high-strength engineering plastic; 15,5 kg (including battery) |
| Sensors | IMU (standard); 1920 × 1080 high-resolution wide-angle camera, DFOV 122°, HFOV 111°, VFOV 70° |
| Interfaces | D1 Edu: Ethernet, USB, power port, SBUS, UART; D1 Pro: no expansion interface |
| Connectivity | Wi-Fi 5.0 / Bluetooth 5.0; operated using a handheld controller and mobile app |
| Wireless | Wi-Fi 5.0 (2,4 GHz, 21 dBm transmitter power), Bluetooth 5.0 |
| Joint encoder | Dual-encoder control; no zero calibration required |
| Processor | 8-core high-performance CPU |
| Software features | Real-time video streaming; standard movements: standing, lying down, damping mode, tilt and height adjustment, horizontal rotation; special movements: jumping forward and upward, standing on two legs, backflip, waving; SDK on D1 Edu, standard interfaces, URDF model, and simulation in Isaac Sim and MuJoCo |
| Expansion module | D1 Edu: Ethernet ×1, USB ×2, power ports ×2, SBUS ×1, UART ×1. D1 Pro: no expansion ports |
| Operating temperature | Between 0 °C and 40 °C |
SEE THE PRODUCT IN ACTION
The introduction video linked from the source product page opens when you press the play button.
PRODUCT INFORMATION SOURCES
This catalog is intended to help explore product information. No commitments are made on behalf of Robotik Çözümler regarding stock, authorized dealers, pricing, warranty, or after-sales service terms.
FREQUENTLY ASKED QUESTIONS
The hardware components and movement capabilities are the same; the main difference is software access and expansion interfaces. D1 Pro offers controller- and app-focused use, while D1 Edu supports sensor/module integration and simulation through its SDK and multiple interfaces.
Standard movements include standing, lying down, damping, tilt and height adjustment, and horizontal rotation. Special movements such as jumping forward and upward, standing on two legs, backflipping, and waving are triggered using the controller or app.
The battery configuration may vary; operating time and range values based on laboratory tests vary depending on usage conditions. Standard accessories for charging and battery replacement are included in the package.
The device's balancing, fall protection, and mechanical design are intended to improve field reliability; however, field performance will vary depending on environmental conditions and usage.
IN THE SAME CATEGORY
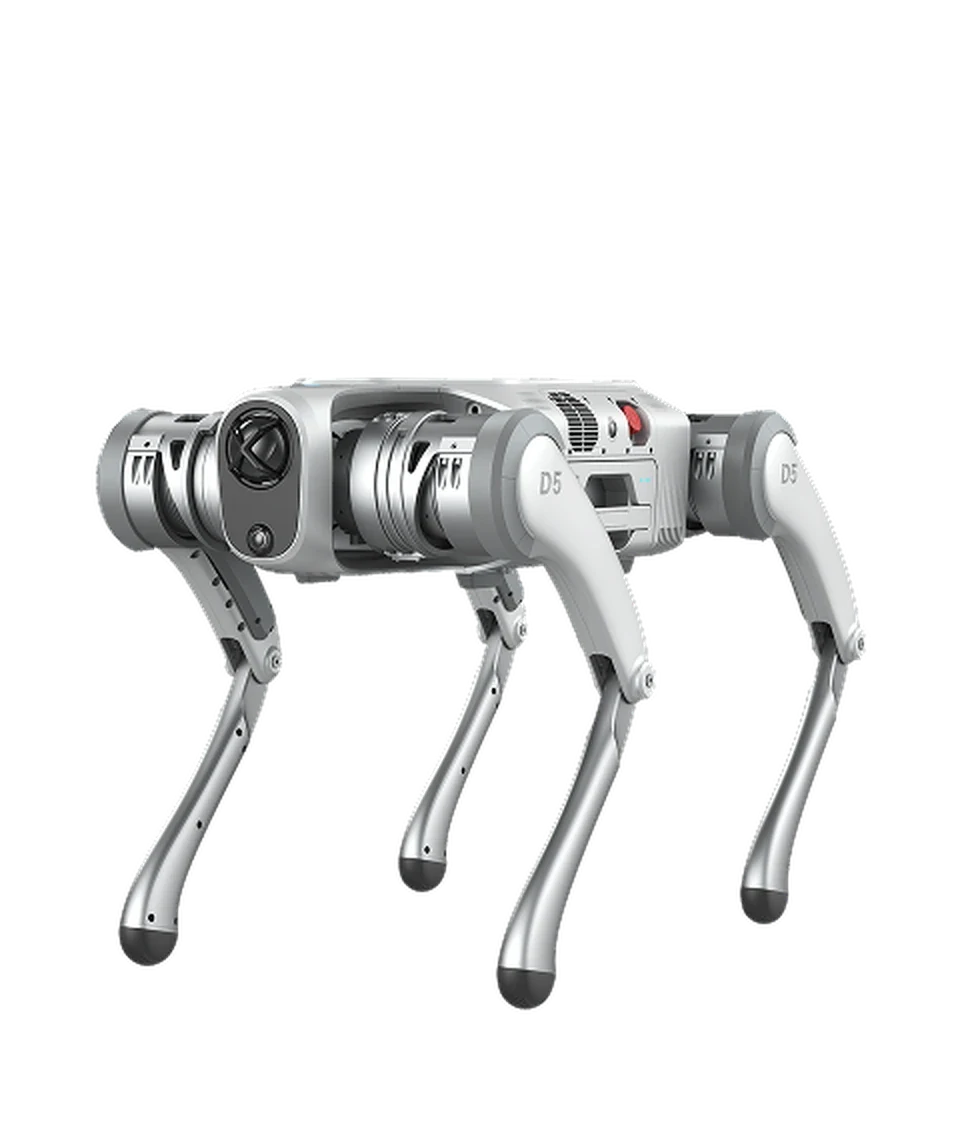 Quadruped robots
PUDU
Industrial autonomous quadruped robot for challenging environments
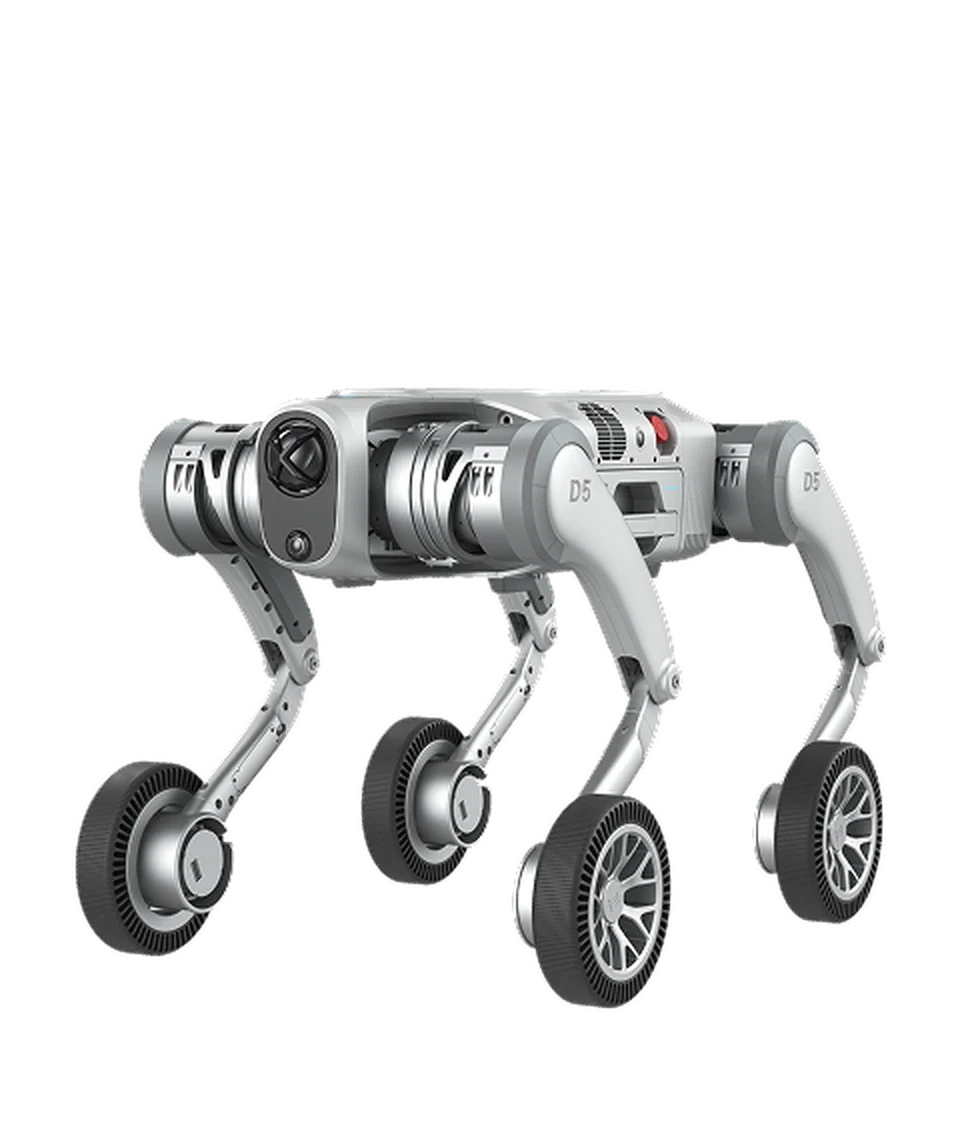 Quadruped robots
PUDU
Industrial-grade autonomous quadruped robot
 Quadruped robots
Unitree
Compact size, industrial capability
NEXT STEP
Start by defining your work area, task, and integration requirements.