




UNITREE · Dexterous robot hands
Unitree Dex3-1
Three-fingered hand with hybrid force and position control
A dexterous hand with hybrid force and position control. Designed to grasp and manipulate objects precisely.
Data collection: responsive and precise
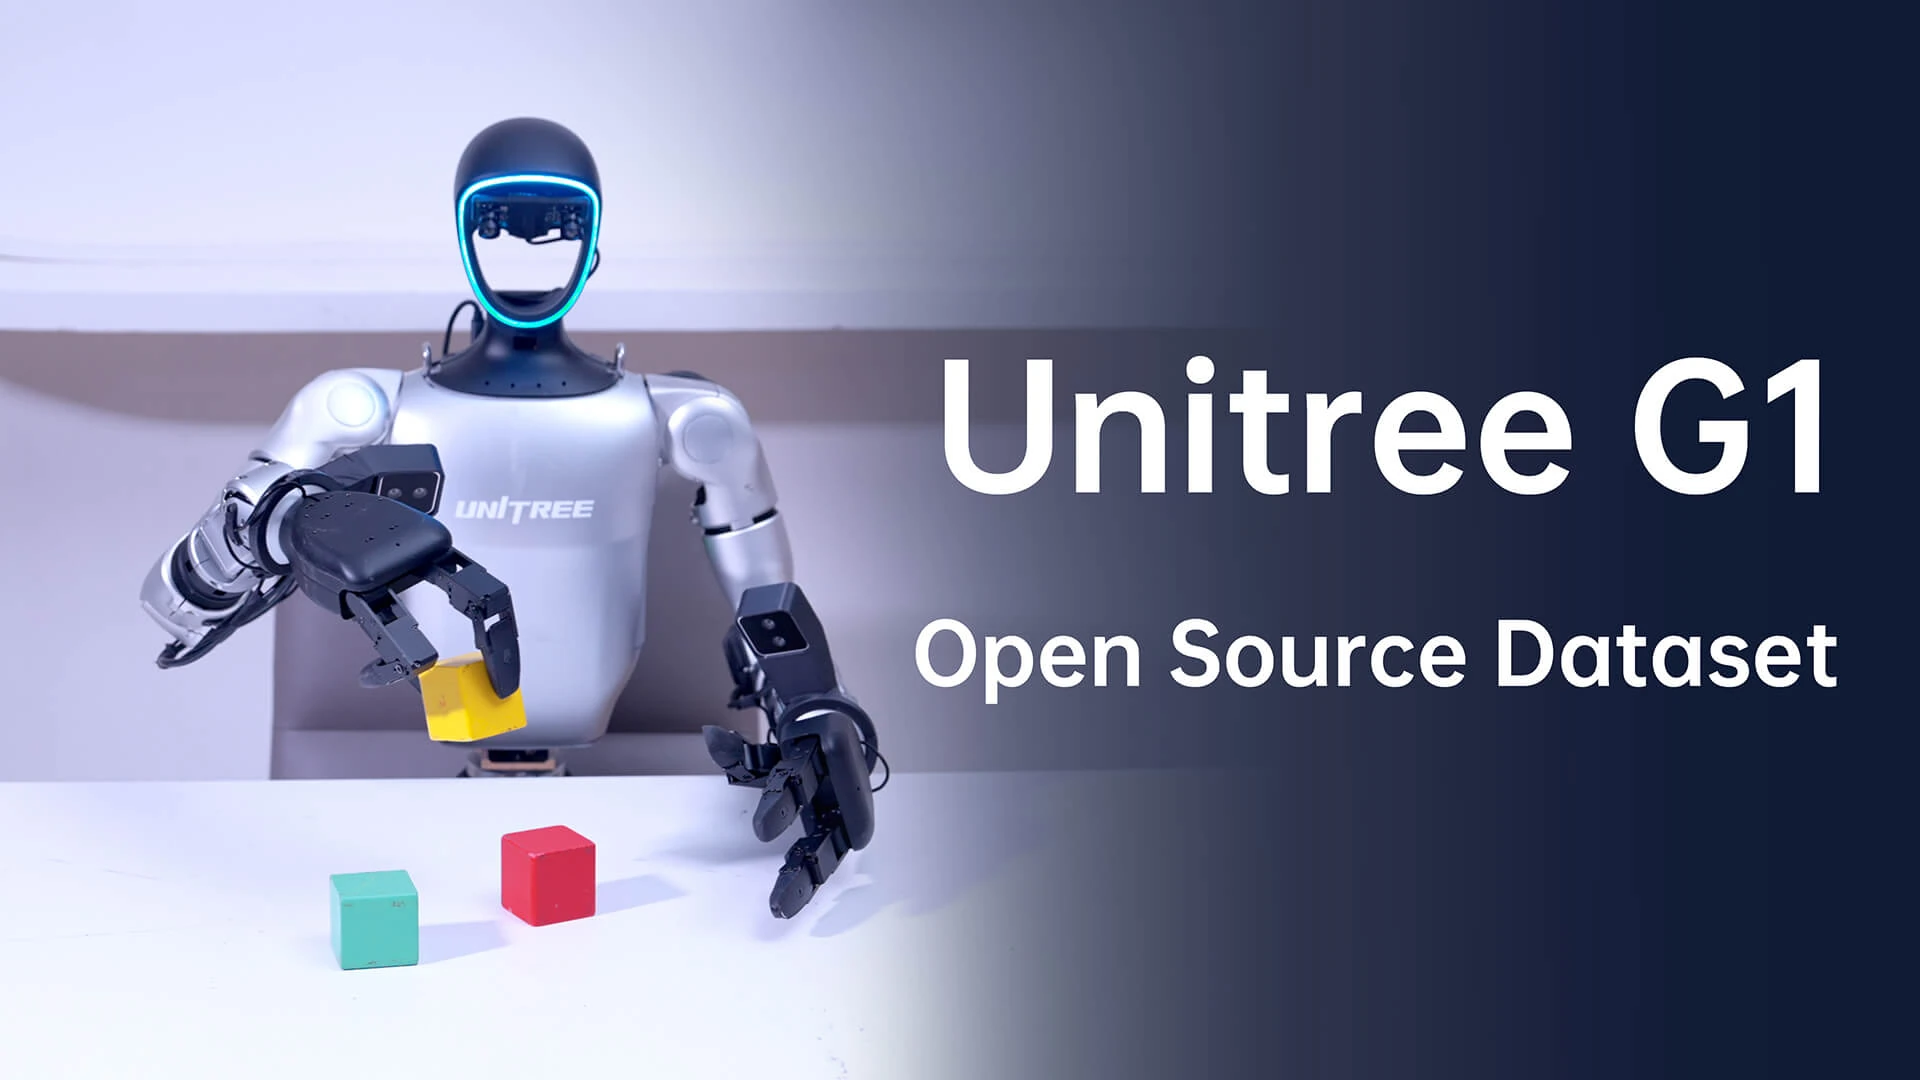
The 7-degree-of-freedom, three-finger Dex3-1 contains 6 micro brushless force-controlled direct-drive joints and 1 micro brushless force-controlled geared joint. Each hand has 33 tactile sensors. It can be used with the G1 humanoid robot to perform a variety of complex movements.
Product parameters
Manufacturer-published body, sensing, software, and micro brushless force-controlled joint data.
| Body weight | 710 g |
|---|---|
| Body dimensions | 175 × 88 × 77 mm |
| Degrees of freedom | 7 |
| Transmission mechanism | 6 direct drive + 1 geared drive |
| Joint angles | Thumb: −60°–60°, −35°–60°, 0°–100°; index: 0°–90°, 0°–100°; middle: 0°–90°, 0°–100° |
| Fingertip repeat positioning accuracy | ±2 mm |
| Operating voltage | 12–58 V |
| Quiescent current | 0,2 A at 58 V |
| Maximum current | 10 A |
| Communication interface | USB 2.0 |
| Operating temperature | −20 °C–60 °C |
| Load condition — palm facing down | Maximum weight 500 g; maximum power 400 W @ 3 s |
| Load condition — palm facing left | Maximum weight 500 g; maximum power 400 W @ 3 s |
| Pressure sensors | 9 sensors; 33 pressure sensors in total |
| Array resolution | 2×2 (palm); 2×2 (finger pad); 3×1 (fingertip) |
| Sensing range | 10 g–2500 g |
| Maximum resistance (without damage) | 20 kg |
| Communication speed | 1000 Hz |
| Byte count in full packet | 1234 / 1270 bytes |
| Perceptual feedback | Joint mode, position, speed, torque, and temperature; voltage/current; pressure sensor value and temperature; IMU data |
| Control feedback | Joint mode, position, speed, torque, stiffness coefficient, and damping coefficient |
| Mini brushless force-controlled joint models | F-1515-108 and F-1515-214 |
| Joint weight | 45 g |
| Joint dimensions | 34,8 × 23,1 × 23,3 mm |
| Reduction ratio | 1:108 / 1:214 |
| Theoretical maximum torque | 0,76 / 1,498 Nm |
| Actual maximum torque | Same direction: 0,49 / 0,86 Nm; opposite direction: 1,37 / 3,1 Nm |
| Maximum rotational speed | 23 / 11 rad/s |
| Maximum line current | 4,76 A |
| Communication control frequency | 1000 Hz |
| Communication method | High Speed Unibus |
| Encoder | Rotor absolute value encoder |
| Joint operating temperature | −20 °C–60 °C |
| IP rating | Not specified ( / ) |
| Joint operating voltage | 12–24 V |
| Motor sensor feedback | Torque, angle, angular velocity, temperature |
| Motor control command | Torque, angle, angular velocity, stiffness, damping |
[1] The dimensions are for the dexterous hand in its flat state. The load data should be read alongside the manufacturer's explanation that the pressure is applied by a vertically downward-pressing cylinder with a diameter of 1 cm, and may vary depending on different usage scenarios. It should also be verified in the actual application.
User manual
Manufacturer-directed link to the Dex3-1 user manual.
Safety and usage note
This product is a robot for civilian use. Avoid hazardous modifications and hazardous use, and comply with applicable local laws and regulations.
Next step for Unitree Dex3-1.
Let's evaluate your model selection and application needs together.